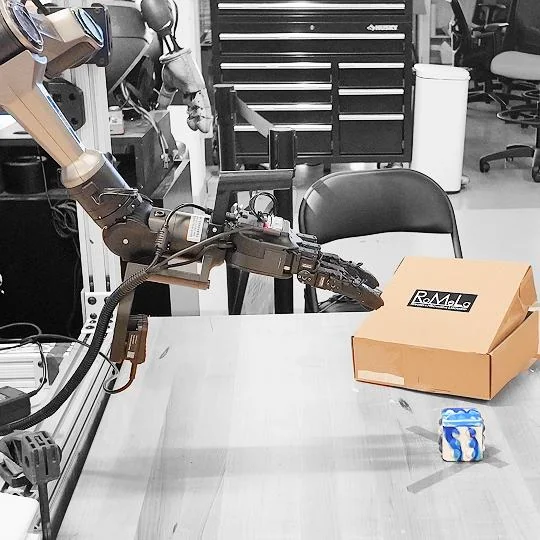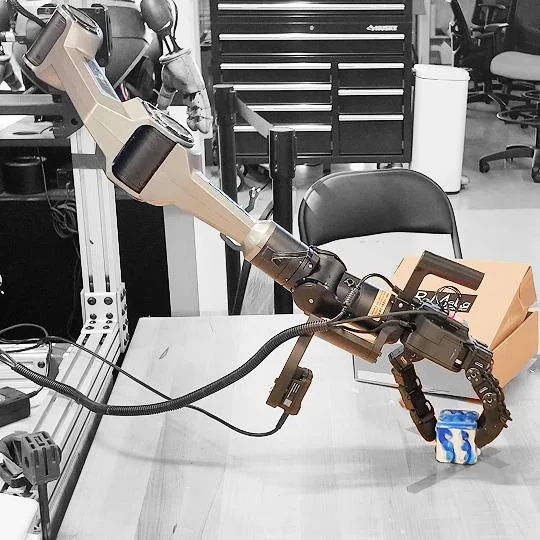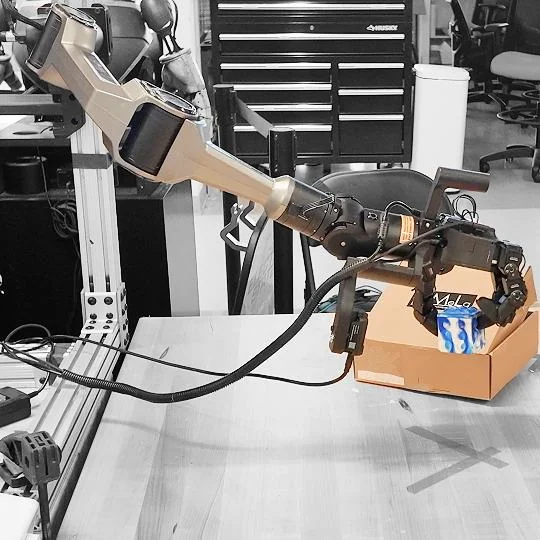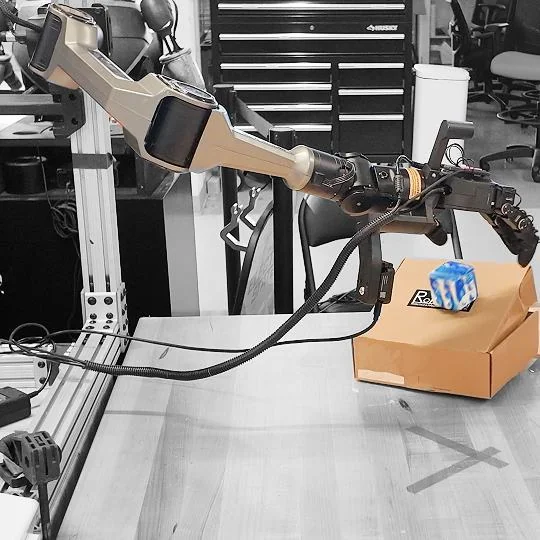
Left hand
Drag the Arm
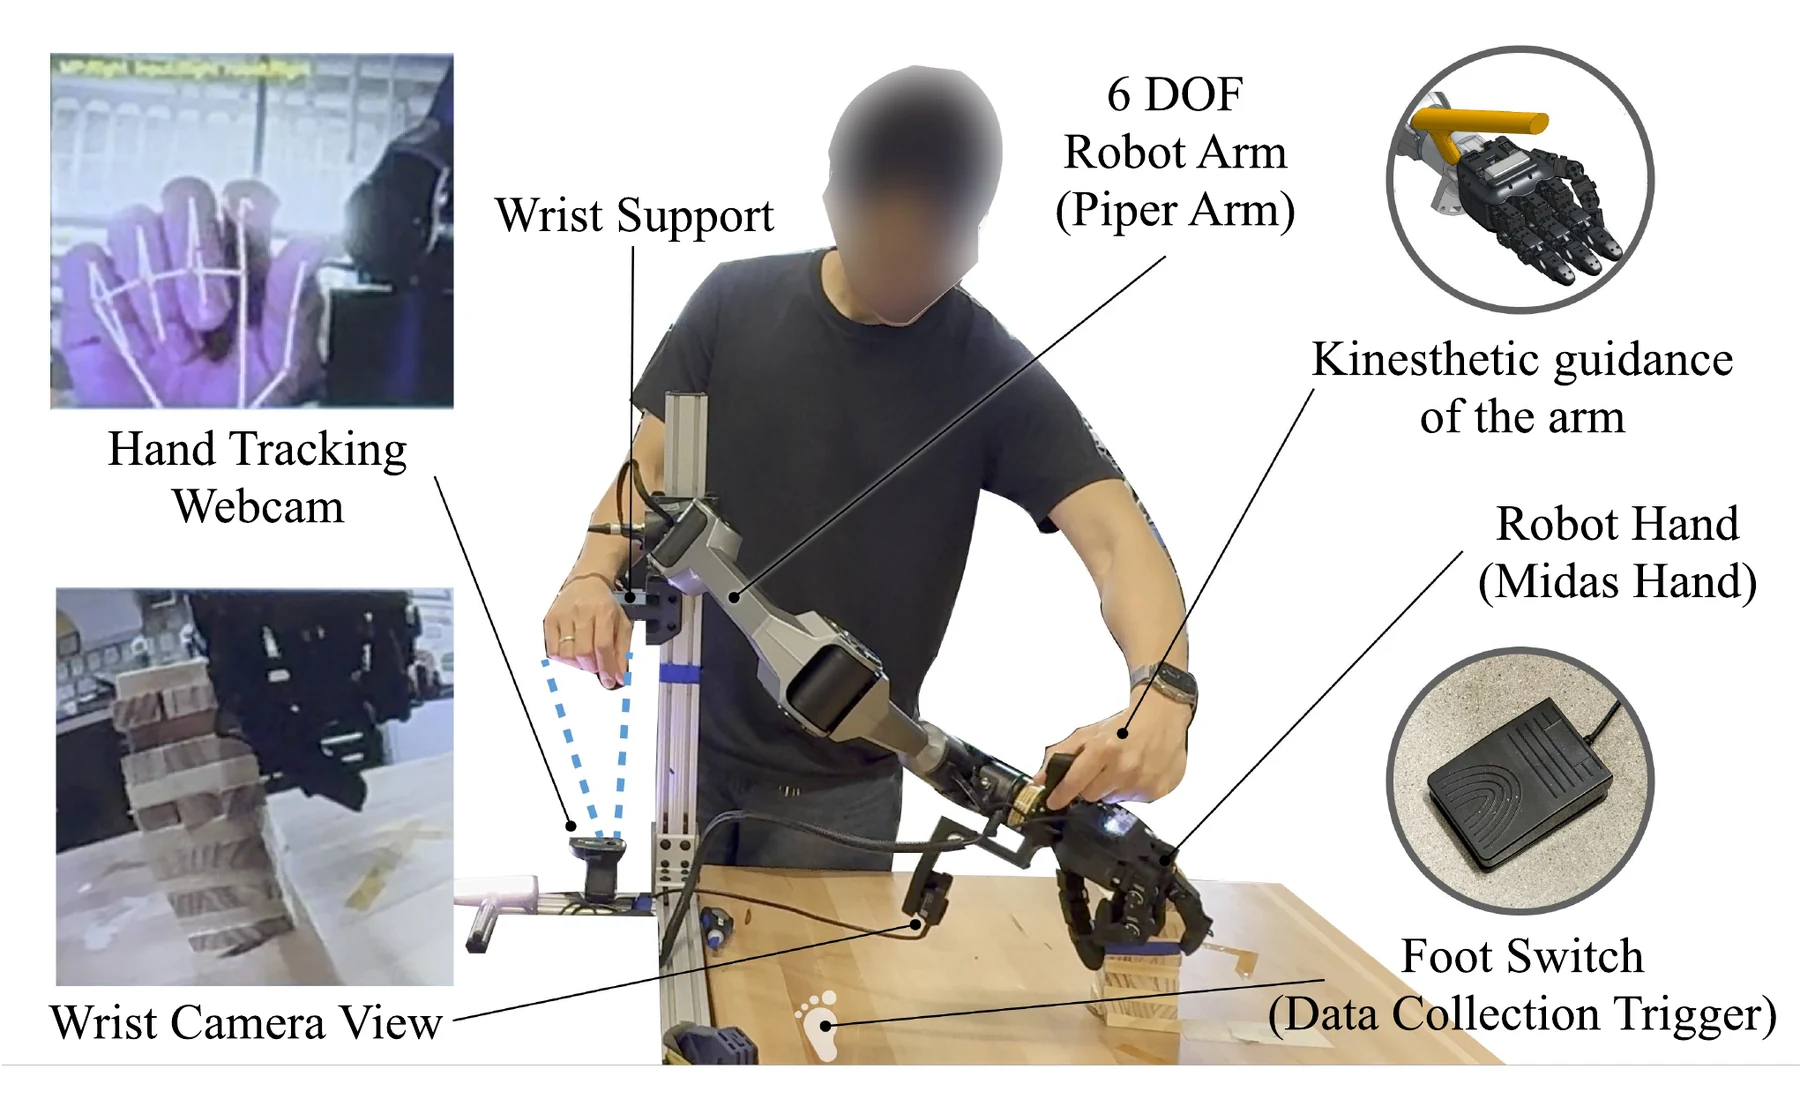
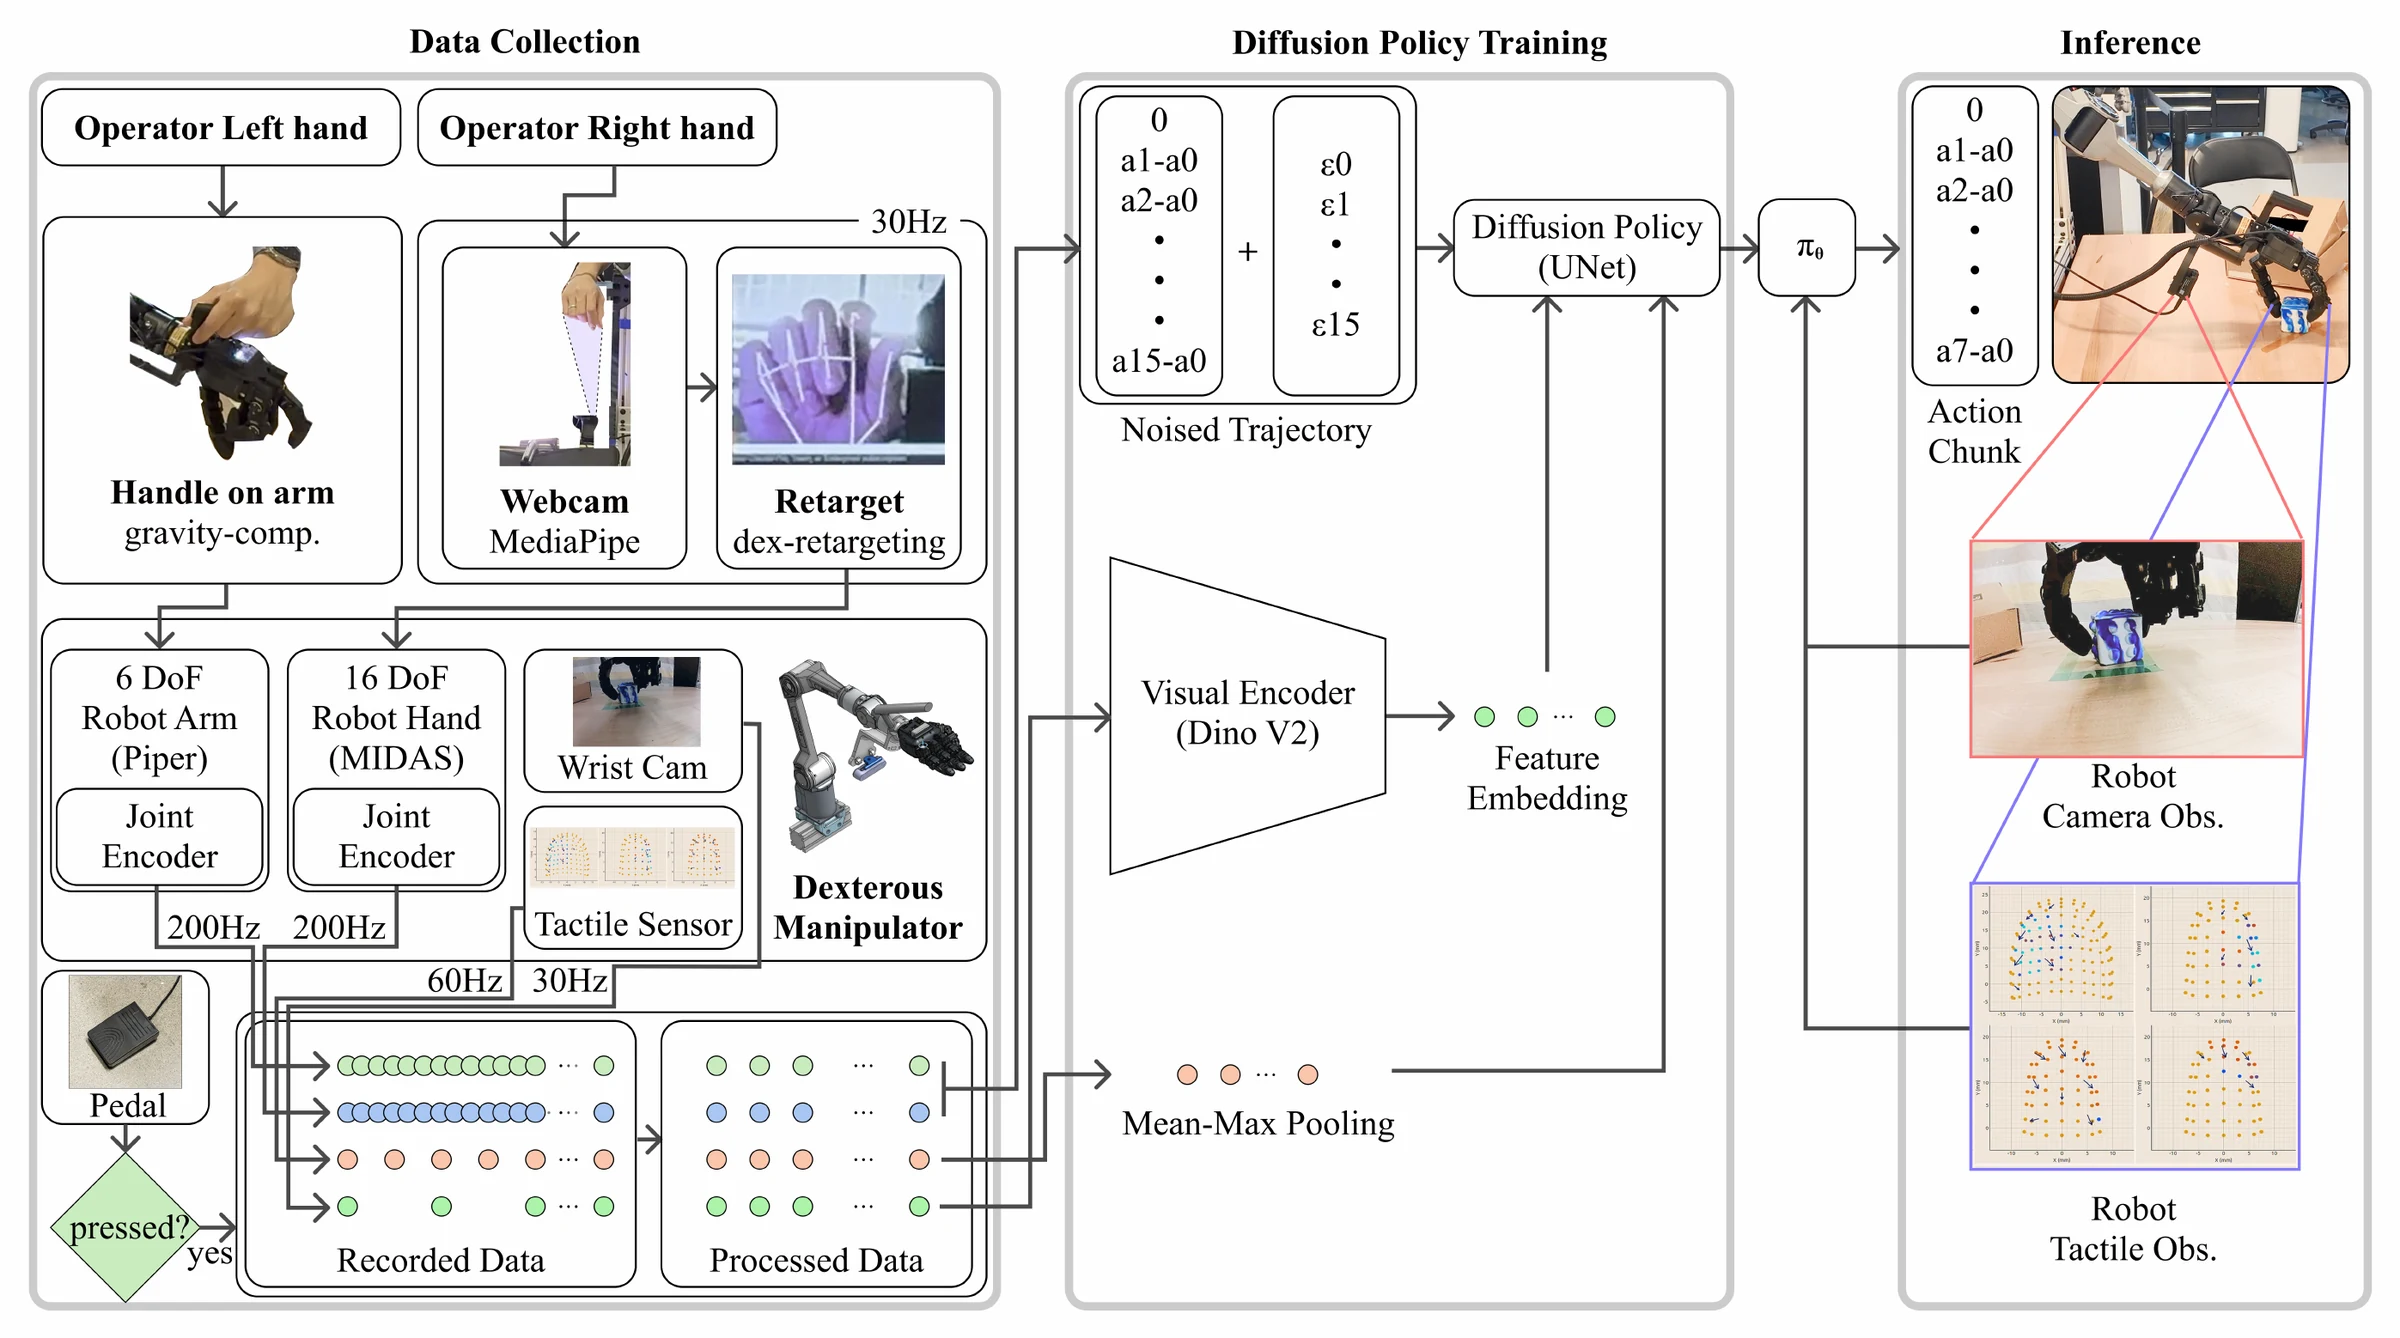
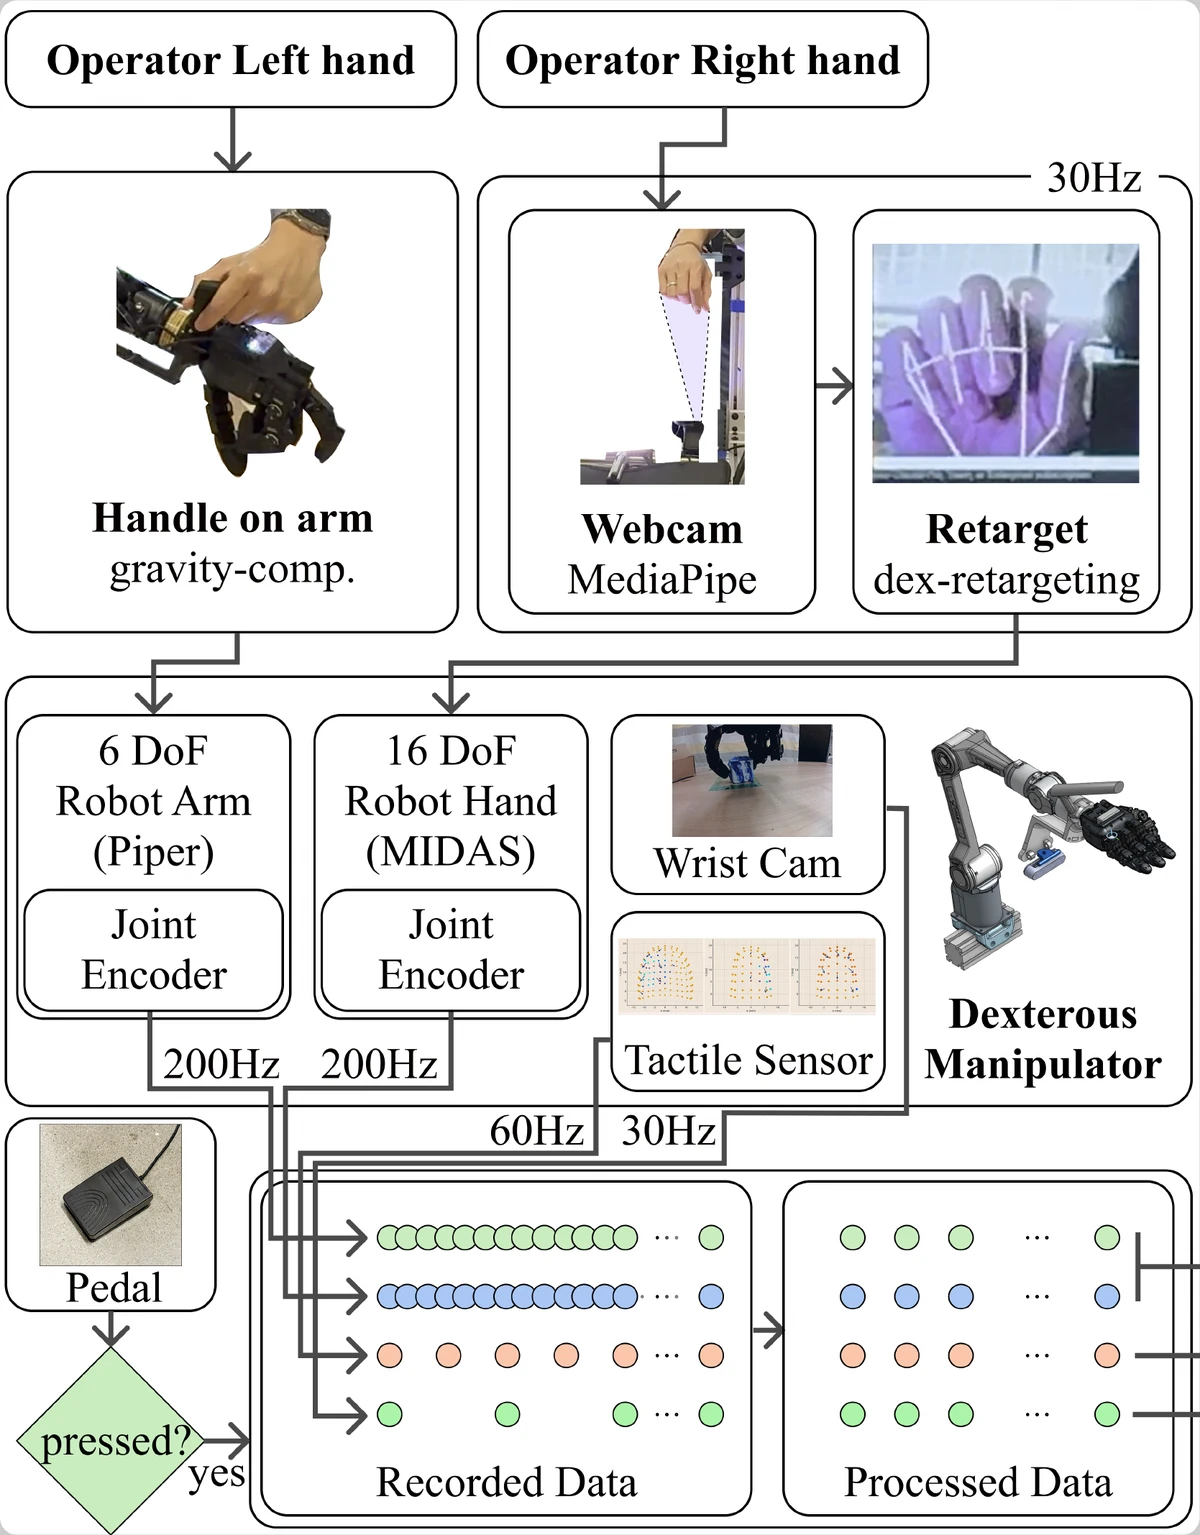
The arm runs in a gravity-compensated drag mode with zero position stiffness and low joint damping. A staged system identification corrects the model gravity torques for payload, torque scaling and friction. Trajectories come straight from the joint encoders, with no pose estimation, retargeting or IK, and the rigid handle lets the operator feel contact.
- 200 Hz
- joint-level control
- 0
- position stiffness
- 0.05 kg
- 3D-printed handle